HAKRC M10 GPS Module with QMC5883 Compass
Technical Highlights
M10050 GNSS Receiver
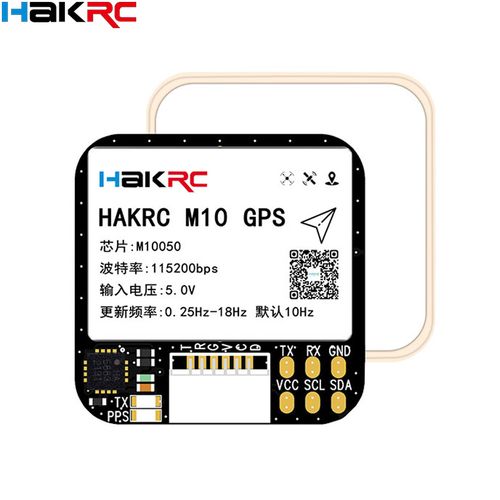
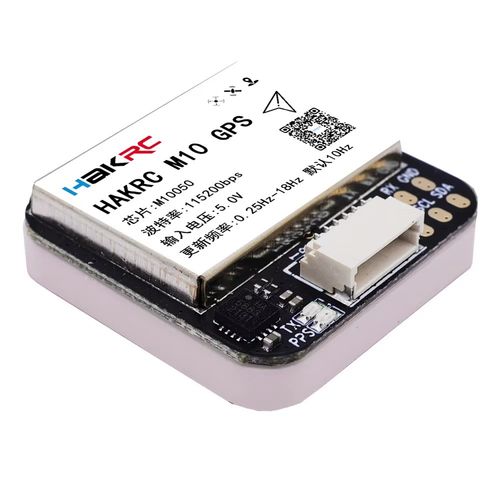
The HAKRC M10 provides satellite positioning for FPV multirotor and RC fixed-wing builds. The module label specifies a default 10 Hz navigation update rate and a serial baud rate of 115200 bps.
Integrated QMC5883 Compass
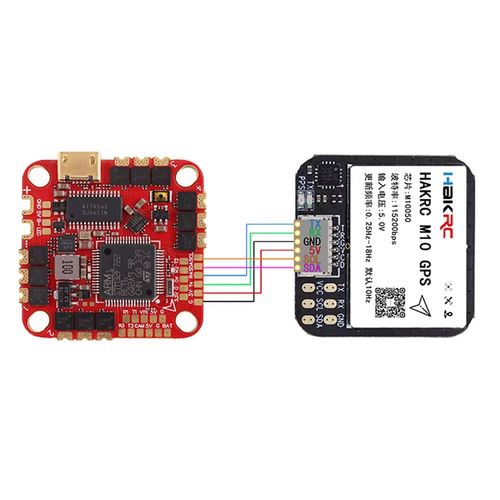
The onboard QMC5883 supplies magnetic heading data over I²C. A flight controller can receive GNSS data through UART and access the compass through its SCL and SDA connections.
5 V Supply and Six-Pin Connection
The board brings power, ground, UART and I²C to a six-pin connector. The same signals are available on labeled solder pads.
Technical Specifications
| Model | HAKRC M10 GPS |
|---|---|
| GNSS Receiver | u-blox M10050 |
| GNSS Platform Support | GPS, Galileo, BeiDou and GLONASS, plus QZSS and SBAS. Enabled systems depend on receiver configuration. |
| Horizontal Accuracy Reference | 1.5 m CEP at receiver level with GPS/Galileo and SBAS/QZSS. Installed performance depends on antenna placement and signal conditions. |
| Navigation Update Rate | 10 Hz default. The module label lists 0.25–18 Hz, subject to receiver configuration. |
| GNSS Messaging | The M10050 platform supports UBX and NMEA over UART. Match the flight-controller setting to the enabled output. |
| Magnetometer | QMC5883, I²C |
| Module Input | 5.0 V DC |
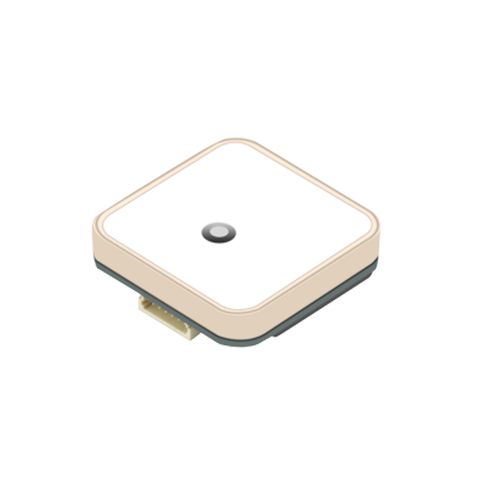
| Listed Module Size | 25 × 25 mm. Confirm thickness and connector clearance for a close-fitting mount. |
Flight-Controller Wiring
| Module Signal | Flight-Controller Connection |
|---|---|
| TX | UART RX |
| RX | UART TX on the same port |
| 5 V / VCC | Regulated 5 V output |
| GND | Ground |
| SCL | I²C SCL for the compass |
| SDA | I²C SDA for the compass |
FAQ
Which connections are needed for GPS and compass data?
GNSS data uses UART TX and RX. To use the onboard QMC5883 compass, also connect I²C SCL and SDA and configure compass support in the flight-controller firmware.
What voltage and baud rate does the module use?
The module label specifies 5.0 V DC input and 115200 bps for the GNSS UART. Match the flight controller's serial settings to the receiver configuration.
What is the default navigation update rate?
The module is labeled for a default rate of 10 Hz and a listed range of 0.25–18 Hz. The usable rate depends on the receiver settings and active constellation combination.
B2B Procurement FAQ
What should I specify when requesting a quotation?
Provide the HAKRC M10 model name, required quantity and any requirements for the QMC5883 compass, GNSS output protocol or harness pinout.
How can I confirm fit with an existing mount or harness?
Request the dimensions, connector clearance and pin assignment for the supplied revision. Include your available mounting space and the mating connector details in the inquiry.
Is the six-wire harness supplied with the module?
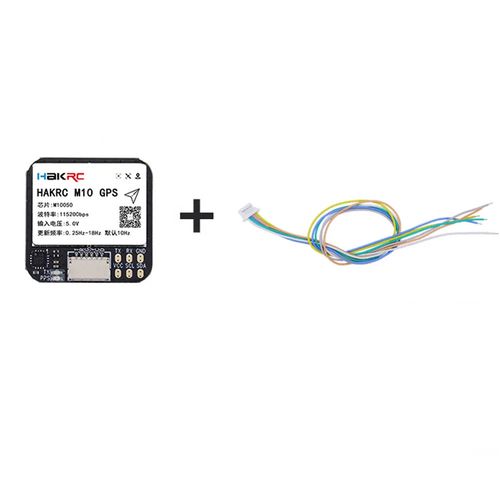
The product image shows a six-wire harness alongside the module. Confirm the included items, order quantity and lead time in the quotation.
Leave Your Message
Products categories
-
HAKRC M10 GPS Module with QMC5883 Compas
-
GY-GPSV3 NEO-M8N UART GPS Module
-
GEPRC GEP-M1025 Series GPS Modules
-
GEPRC GEP-M10-DQ GPS Module with Compass
-
GEPRC GEP-M10 Series GPS Module (GEP-M10
-
Foxeer M10Q-250 GPS 5883 Compass Module
-
FlyFishRC M10 Mini GPS Module
-
FLY WING H1 6CH GPS Helicopter Flight Co
-
BZGNSS P15 Pro / P18 Pro / P25 Pro FPV G
-
Bainianxing BU-1025TF U-blox M10 GNSS GP